 README
- ::stateAnalysis::state
- TCamPoint
- TConstraintDiagnostic
- ::statusCrossingCheck::status
- TCrossingReport
- TCrossingWitness
- TDiagnostics
- TEdgeLocation
- ::codeErrorCode::code
- ::exit_codeErrorCode::exit_code
- TGeometry
- TLaw
- TLocation
- TMetrics
- TMotion
- TProgram
- TSamplingComparison
- TSamplingLevel
- TSearchError
- TSearchResult
- TSegment
- ::export_profileSession::export_profile
- ::runSession::run
- Vanalyze
- Vchecked_export
- Vcompare_sampling
- Vcontact
- Vcontract_json
- Vcrossing_report
- Vcsv
- Vdiagnose
- Vdxf_mm
- Verror_exit_code
- Vevaluate
- Vexample_program
- Vfinite
- Vgenerator_json
- Vinput_limit_bytes
- Vlocate_angle
- Vlocate_edge
- Vlocate_sample
- Vmeasure
- Vnormalized
- Vprofile_crossings
- Vprogram
- Vresult_exit_code
- Vrun_json
- Vsample
- Vsampled_acceptance
- Vsearch_base
- Vsession
- Vsvg
- Vtimed
- Vvalidate_geometry
- Vvalidate_segments_json
mooncam
Radial roller cam synthesis and kinematic analysis in MoonBit
cam
kinematics
mechanical-design
Author
Version
0.4.1
License
MIT
Repository
Last updated
5 days ago
Downloads
37
#MoonCam

用 MoonBit 编写的凸轮设计工具。给出升程、回程、停歇和机构尺寸,就能查看凸轮轮廓,检查压力角,找到需要调整的位置,并导出图形和数据。
适合机械课程设计、教学模型和凸轮方案初选。目前支持平面盘形凸轮与直动滚子从动件,可设置正负偏置,转速保持恒定。
在线版无需安装。计算在浏览器本地进行,输入参数不发送到服务器。
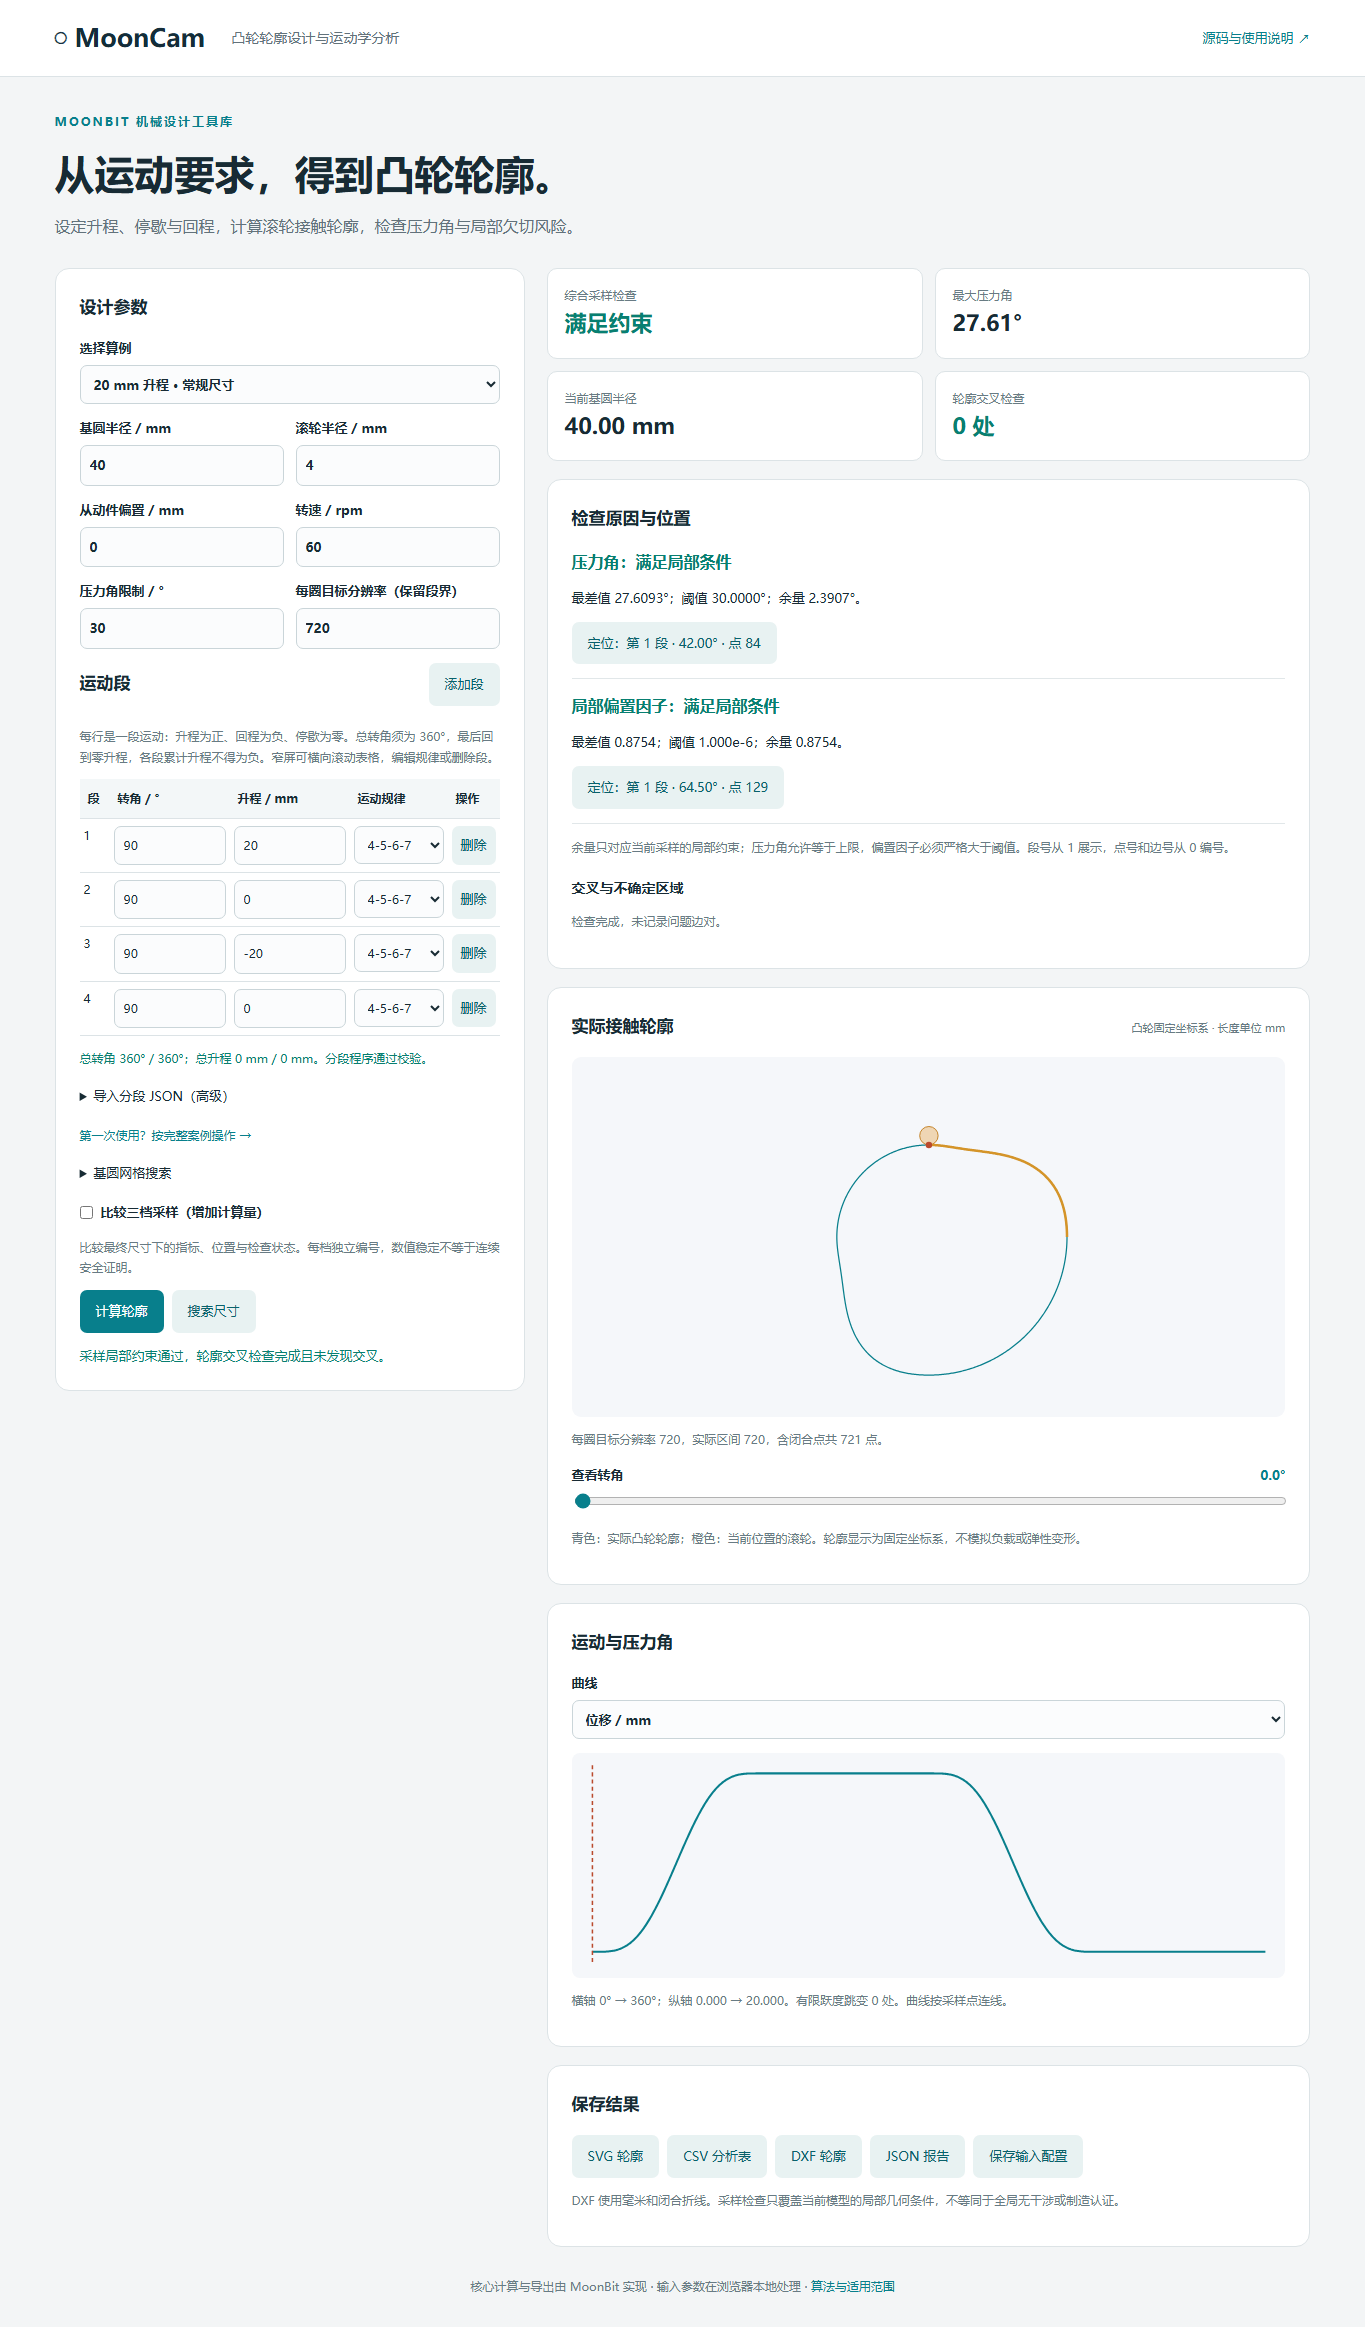
#先试一个例子
打开工作台,选择“小基圆 · 压力角不满足”,点击“计算轮廓”。这个例子的升程是 20 mm,基圆半径只有 5 mm,最大压力角约 59.02°,超过设置的 30° 限制。
点击压力角诊断中的定位按钮,可以看到问题所在的运动段和轮廓位置。再使用“基圆网格搜索”,按 1 mm 间隔搜索 5~100 mm,会得到 36 mm 的候选,复核压力角约 29.52°。
把左侧基圆改为 36 mm,勾选“比较三档采样”后重新计算,就能检查采样加密后的变化。最后保存输入和报告,按需要下载 CSV、SVG 或 DXF。
完整案例包含调整前后对照、三档采样结果和可重复运行的输入文件。
#可以用它做什么
- 分段编辑升程、停歇和回程,每段可选摆线、3-4-5 或 4-5-6-7 运动规律。
- 查看位移、速度、加速度、跃度、压力角和实际滚轮接触轮廓。
- 检查局部几何条件和轮廓折线交叉,定位超限点及相关边。
- 搜索基圆候选尺寸,比较不同采样密度下的指标与检查结果。
- 保存 JSON 输入和报告,导出 CSV 数据、SVG 图形及毫米制 DXF 闭合折线。
运动学、接触几何、搜索、判定和导出内容均由 MoonBit 实现;JavaScript 负责网页交互与 Node.js 文件读写。运行时不依赖 Python、CAD 或远程计算服务。
#怎样理解“通过”
通过表示本次采样满足局部约束,且轮廓折线交叉检查完成、确定零交叉。如果几何关系无法确定,页面会单独提示,不会算作通过。
加密采样可以帮助观察结果是否稳定,但不能证明连续轮廓没有干涉。搜索得到的是有限网格上的首个通过候选。项目尚不包含强度、载荷、磨损、公差或加工分析,导出 DXF 也不代表可以直接加工。详细说明见算法与适用范围。
#在自己电脑上运行
需要 MoonBit 工具链和 Node.js 22+。最低要求 moonc 0.10.16;仓库固定验证的 MoonBit 版本为 0.10.16+b1a0e846e。
git clone https://github.com/huahai29/mooncam.git
cd mooncam
npm run build
npm run serve
终端出现监听地址后,打开 http://127.0.0.1:4173/ 。使用期间保持终端运行;下次打开只需再次执行 npm run serve。
也可以直接生成文件:
node bin/mooncam.mjs examples/workshop.json --out artifacts/workshop输出目录包含输入配置、JSON 报告、CSV、SVG 和 DXF。安装说明、更多算例、退出码及页面打不开时的处理方法见本地运行。
#在 MoonBit 项目中使用
moon add huahai29/mooncam@0.4.1在 moon.pkg 中导入:
import {
  "huahai29/mooncam" @cam,
  "moonbitlang/core/math",
}
调用示例:
let p = @cam.example_program(@cam.Polynomial4567)
let g : @cam.Geometry = {
  base_radius: 40.0,
  roller_radius: 4.0,
  offset: 0.0,
}
match @cam.analyze(p, g, 720, @math.PI / 6.0, 2.0 * @math.PI) {
  Ok(a) => println(a.max_pressure * 180.0 / @math.PI)
  Err(message) => println(message)
}
库使用弧度、rad/s 和一致的长度单位;网页与 JSON 使用毫米、角度和 rpm。完整示例在 examples/library,接口签名见公共 API。
Mooncakes 0.4.1 提供核心库;网页和 CLI 从仓库运行。在线版跟随 main 分支;发行版本说明见0.4.1。网页页脚和新报告会记录实际引擎的版本与源码指纹,复算时请一并保留。
#文档与开发
- 输入输出说明:JSON 配置、单位和导出字段。
- 位置、诊断与采样比较:如何理解余量、点号和交叉证据。
- 接口契约:状态、上限与错误码。
- 架构说明与设计取舍:代码组织和算法选择。
- 验证记录与固定验收用例:测试方法、独立数值对照和检查命令。
- CAD 导入验收:FreeCAD 原生导入的尺寸、闭合与坐标对照。
- 版本追溯与性能护栏、更新记录与后续计划。
当前测试包括四后端各 62 组核心测试(54 组固定用例 + 8 组随机性质用例)、23 组集成测试、8 组 JSON 契约性质测试(含 1,500 例结构变异模糊输入)和 13 组浏览器测试。独立数值对照用 Bernstein 形式与参数曲率另一条路线核对 205 组参数、149,983 个采样点与 171,942 条断言,另用 40 位十进制参考复核 402 个点(坐标差 ≤8.7e-16);CI 在 Windows 与 Linux 上分别生成一致性清单并比对。对应提交的运行结果见 GitHub Actions。参与开发或反馈问题请看贡献说明。
#许可证
Analysis
pub(all) struct Analysis {
  points : Array[CamPoint]
  pressure_sample_index : Int
  offset_factor_sample_index : Int
  max_pressure : Double
  pressure_angle : Double
  min_offset_factor : Double
  min_offset_factor_angle : Double
  max_velocity : Double
  max_acceleration : Double
  max_jerk : Double
  jerk_jumps : Int
  sampled_local_feasible : Bool
  crossings : CrossingCheck
  crossing_witnesses : Array[CrossingWitness]
  crossing_witnesses_truncated : Bool
  sampled_feasible : Bool
  nominal_resolution : Int
}CamPoint
pub(all) struct CamPoint {
  theta : Double
  motion : Motion
  pitch_x : Double
  pitch_y : Double
  x : Double
  y : Double
  normal_x : Double
  normal_y : Double
  pressure : Double
  curvature : Double
  offset_factor : Double
}
Pitch center, cam contact, outward normal and differential geometry.
ConstraintDiagnostic
pub(all) struct ConstraintDiagnostic {
  code : String
  value : Double
  limit : Double
  margin : Double
  passed : Bool
  location : Location
}
Margin is positive on the permitted side. Offset-factor equality is rejected.
CrossingCheck
pub(all) enum CrossingCheck {
  NotChecked
  Checked(Int)
  Indeterminate(Int, Int)
  Failed(String)
}
Explicit completion state; unchecked and failed are never a zero count.
CrossingReport
pub(all) struct CrossingReport {
  crossings : Int
  pair_visits : Int
  uncertain_pairs : Int
  witnesses : Array[CrossingWitness]
  witnesses_truncated : Bool
}
Broad-phase work counters permit regression tests without wall-clock claims.
CrossingWitness
pub(all) struct CrossingWitness {
  kind : String
  edge_a : Int
  edge_b : Int
}
Edge i joins input points[i] and points[i+1]. No invented intersection point.
Diagnostics
EdgeLocation
ErrorCode
pub(all) enum ErrorCode {
  InvalidJson
  InvalidRequest
  InputTooLarge
  CalculationFailed
  CheckIndeterminate
  NoCandidateFound
  InternalError
  NoResult
}Geometry
pub(all) struct Geometry {
  base_radius : Double
  roller_radius : Double
  offset : Double
}
at zero cam angle. Cam coordinates use a clockwise angular parameter.
Law
pub(all) enum Law {
  Cycloidal
  Polynomial345
  Polynomial4567
}
Motion law on a normalized rise from zero to one.
Location
pub(all) struct Location {
  sample_index : Int?
  segment_index : Int
  theta_rad : Double
  segment_start_rad : Double
  segment_end_rad : Double
  law : String
  periodic_endpoint : Bool
}
Zero-based IDs. Sample IDs are local to one mesh, never cross-resolution IDs.
Metrics
pub(all) struct Metrics {
  pressure_sample_index : Int
  offset_factor_sample_index : Int
  max_pressure : Double
  pressure_angle : Double
  min_offset_factor : Double
  min_offset_factor_angle : Double
  max_velocity : Double
  max_acceleration : Double
  max_jerk : Double
  jerk_jumps : Int
  sampled_local_feasible : Bool
  sample_count : Int
  nominal_resolution : Int
}
Scalar-only analysis. Local feasibility excludes topology by definition.
Motion
pub(all) struct Motion {
  s : Double
  v : Double
  a : Double
  j : Double
}
Values and derivatives with respect to the independent variable.
Program
Validated closed program. Constructor owns a copy of the segment array.
SamplingComparison
pub(all) struct SamplingComparison {
  levels : Array[SamplingLevel]
  pressure_change : Double
  offset_factor_change : Double
  state_consistent : Bool
}
Last two levels' absolute metric changes; no convergence verdict or error bound.
SamplingLevel
pub(all) struct SamplingLevel {
  nominal_resolution : Int
  sample_count : Int
  pressure : ConstraintDiagnostic
  offset_factor : ConstraintDiagnostic
  crossings : CrossingCheck
  state : String
}SearchError
pub(all) enum SearchError {
  InvalidInput(String)
  NumericalFailure(String)
  IndeterminateGeometry(String)
  NoCandidate(Int)
}
Typed errors distinguish exhausted grids from invalid input and failures.
SearchResult
First accepted point on a finite grid, not a continuous optimum.
Segment
Angular extent in radians; signed lift in the chosen length unit.
Session
analyze
Full sampled analysis, including topology. Not a continuous geometry proof.
checked_export
Checked boundary for external point arrays. Raw formatters assume valid samples.
compare_sampling
fn compare_sampling(p : Program, g : Geometry, resolutions : Array[Int], pressure_limit : Double, omega : Double) -> Result[SamplingComparison, String]Full independent sampled checks at each level, not continuous certification.
contact
Synthesize the roller-envelope contact point, not a radial subtraction.
contract_json
fn contract_json() -> StringMachine-readable source for checked-in contract documentation.
crossing_report
Adversarial overlap has a bounded work budget and returns an incomplete check.
csv
Export angular derivatives explicitly; time scaling is given in report JSON.
diagnose
Analysis and Program must come from the same calculation.
dxf_mm
ASCII DXF R2000, closed LWPOLYLINE in millimetres. Coordinates are sampled.
error_exit_code
fn error_exit_code(code : String) -> IntHost fallback: unknown error codes are errors, never successful completion.
evaluate
Angular derivatives ds/dtheta, d2s/dtheta2 and d3s/dtheta3.
example_program
A 20-unit rise / dwell / return / dwell example.
generator_json
Build provenance describes the compiled engine, independently of the host.
input_limit_bytes
fn input_limit_bytes() -> IntShared wire limit in UTF-8 bytes, exported to CLI hosts.
locate_angle
Exact angle query in [0, 2pi]; no implied nearest sample. 2pi uses segment 0.
locate_edge
Edge i connects samples i and i+1; its owning segment is the start's segment.
locate_sample
measure
Metrics only: no CamPoint collection, trigonometry, topology or exports.
normalized
Evaluate a normalized law. Internal callers validate u in [0, 1].
profile_crossings
Compatibility convenience API returning a count only for a determinate check.
Err includes both uncertain contacts and failed checks; never treat it as zero
or parse its message for classification. Prefer crossing_report for structured
uncertainty counts and bounded edge witnesses.
program
Build a closed one-revolution program starting at zero lift.
run_json
fn run_json(input : String) -> StringStateless request API. Use a Session to export a previous result without recomputation.
sample
The nominal resolution sets density; all segment boundaries are preserved.
sampled_acceptance
Pure state combination: a failed or absent check can never accept a profile.
search_base
fn search_base(p : Program, roller_radius : Double, offset : Double, lower : Double, upper : Double, intervals : Int, resolution : Int, pressure_limit : Double, omega : Double) -> Result[SearchResult, SearchError]The coarse pass allocates no coordinates; the fine pass returns the metrics and
the coordinates that topology verification consumes.
svg
Font-independent SVG. Model y is up; SVG y is down.
timed
Physical time derivatives for a positive constant shaft speed in rad/s.
validate_segments_json
fn validate_segments_json(input : String) -> StringValidate a JSON segment array without sampling or changing a Session cache.
Totals are present for numeric arrays, including programs which do not close.
Install
Download zipRadial roller cam synthesis and kinematic analysis in MoonBit
camkinematicsmechanical-design

 MIT

 Updated 5 days ago
 37 downloads